From BigGo Finance · BigGo Finance · · 50s
Ant Group's Robbyant Open-Sources Tactile Model
Ant Group's Robbyant releases open-source tactile model for robots.
In brief
Ant Group's Robbyant releases open-source tactile model for robots. Ant Group's Robbyant open-sourced LingBot-Touch, a tactile foundation model that boosts robot task success rates by 14-26 percentage points across sensors. Originally reported by BigGo Finance.
Robbyant Open-Sources LingBot-Touch
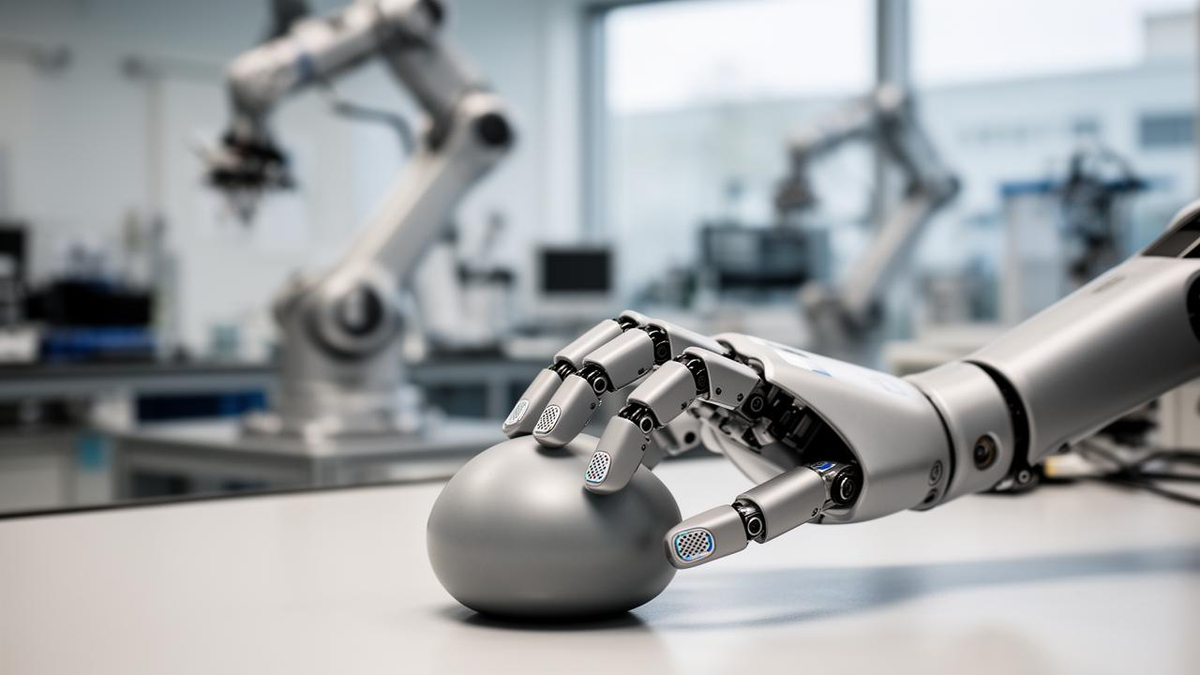
Ant Group's Robbyant open-sourced LingBot-Touch, a tactile foundation model pre-trained on nearly 5,000 hours of real-world tactile data.
Supports Three Sensing Principles
The model supports magnetic tactile, vision-based tactile and piezoresistive sensing to convert signals into a shared tactile representation.
Boosts Task Success Rates
In 26 real-machine tests, pairing two robotic hands with four action models, task success rates rose by 14 to 26 percentage points with tactile input.
Goal: One Brain for All Robots
Robbyant aims to build 'one brain shared by all robots' through sensor-agnostic tactile systems.
“all robots sharing one brain”
The short version
Ant Group's Robbyant open-sourced LingBot-Touch, a tactile foundation model that boosts robot task success rates by 14-26 percentage points across sensors.