From TechCrunch · Tim Fernholz · · 3m
Eka's robot learns to pick things up
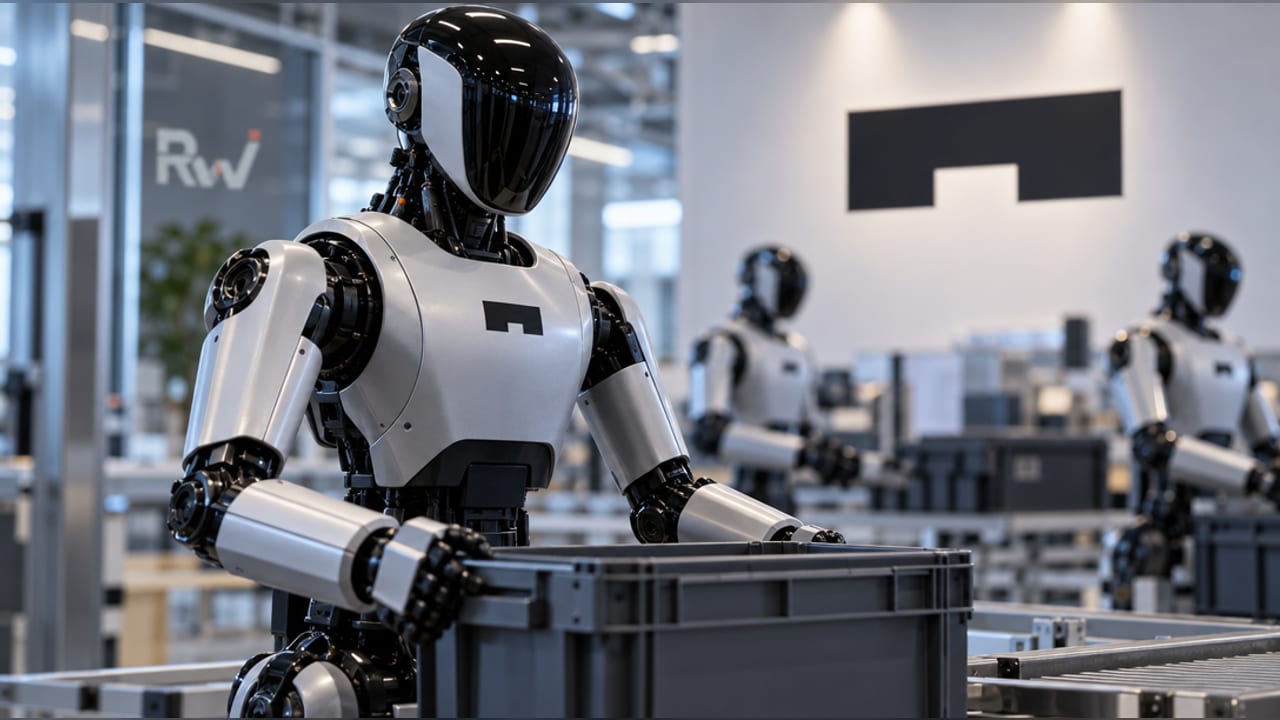
A startup founded by MIT and Google DeepMind researchers has built a robot that picks objects with superhuman speed and gentleness, raising one point four five billion dollars at its latest funding round.
In brief
A startup founded by MIT and Google DeepMind researchers has built a robot that picks objects with superhuman speed and gentleness, raising one point four five billion dollars at its latest funding round. Eka Robotics closed a one hundred fifty million dollar Series A round valuing it at one point four five billion…
The problem with robot hands
Robots still struggle to pick things up reliably despite billions in investment and endless videos fed into deep learning models.
Eka's new approach
Eka Robotics, founded by MIT professor Pulkit Agrawal and former Google DeepMind researcher Tuomas Haarnoja, built a manipulation system with a force-sensitive gripper and a new deep-learning model.
One point four five billion valuation

Eka closed a one hundred fifty million dollar Series A round led by venture funds a16z and F-Prime, valuing the company at one point four five billion dollars post-money.
Superhuman performance claimed
Raghu Raguram, the a16z general partner who co-led the fundraising, said Eka robots are already exceeding superhuman performance for certain tasks and will achieve it across many dexterous manipulation tasks soon.
“They are already exceeding superhuman performance for certain tasks, and so we think over the next few months there will be superhuman performance in many dexterous manipulation tasks.”
Veteran roboticists impressed
Kris Hauser, a professor at the University of Illinois Urbana-Champaign, said Eka's robot had a wow factor compared to other recent robot demos he had seen.
Adaptation without retraining
Hauser noted the Eka robot could adapt to many different objects without retraining and showed humanness by trying repeatedly if it failed the first time.
Speed and reliability metrics

The robot picks about one thousand five hundred objects weighing up to one kilogram per hour, compared to about six hundred for a human, and reliably picks up objects more than ninety five percent of…
Force sensing over vision
Eka built a vision-force-action model focusing on the relationship between language, force inputs and actions, rather than a vision-language-action model that most competitors use.
Why force matters
Agrawal told TechCrunch that vision tells you roughly where an object is, but the actual grabbing and searching happens through forces, not sight.
“Vision is not the primary way in which you close this last millimeter problem.”
Simulation at scale
Eka uses a physics simulator to model forces the robot encounters while grasping, creating a reinforcement learning environment that generates thousands of hours of robot experience in minutes.
Bridging the gap
Agrawal argues Eka is bridging the generality-performance gap that plagues modern robotics, where general models are not very good and highly capable models work only on single tasks.
“What EKA is bridging is the generality-performance gap, which plagues a lot of modern robotics.”
Industrial deployment challenges
Eka is working in secretive pilots with industrial customers on pick-and-place and wire manipulation, but the leap from lab to production line remains a major challenge.
Durability targets ahead
Eka's gripper hardware costs less than one thousand dollars and is rated for five million duty cycles, but the goal is to reach the twenty million cycle standard set by industrial arms.
Starting with two verticals
Agrawal said Eka is being pragmatic by focusing on pick, arrange, place and wire handling as initial verticals, aiming for home runs before expanding to other tasks.
“Once we have made home runs on them, the sky is the limit in how much we can do with the approach we are developing.”
What matters most
Eka Robotics closed a one hundred fifty million dollar Series A round valuing it at one point four five billion dollars, backed by a16z and F-Prime, after building a robot that manipulates objects faster and more reliably than humans.